Actuators for Physical AI
Backed by Y Combinator, Founders Inc. and UP.Partners. Founding team from Apple.
Today's robots are numb.
Their software is smart, but most of their bodies can't feel what they touch, so developers write more and more code to work around it.
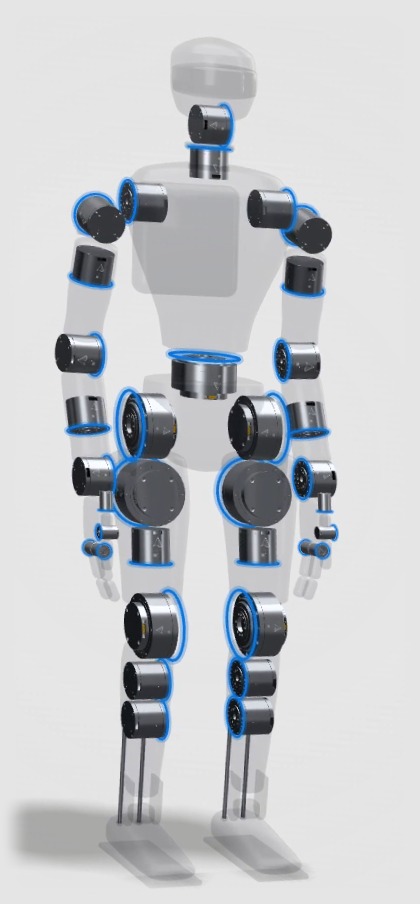
Silica builds a nervous system into the hardware, so every joint feels the world around it.
Today's actuators can feel things as light as a tennis ball. Silica's actuators can feel things as light as a paperclip.
Most robots estimate force from the current in their motors. Silica joints measure torque at the output, where the joint meets the load, so every demonstration, rollout and contact is recorded as real force.
- Applied force0 g
- Silica, measured at the joint0 g
- Motor-current estimate0 g
Press and hold to apply load
Use cases
Lab automation
Training
Toy biped
Swipe for more
